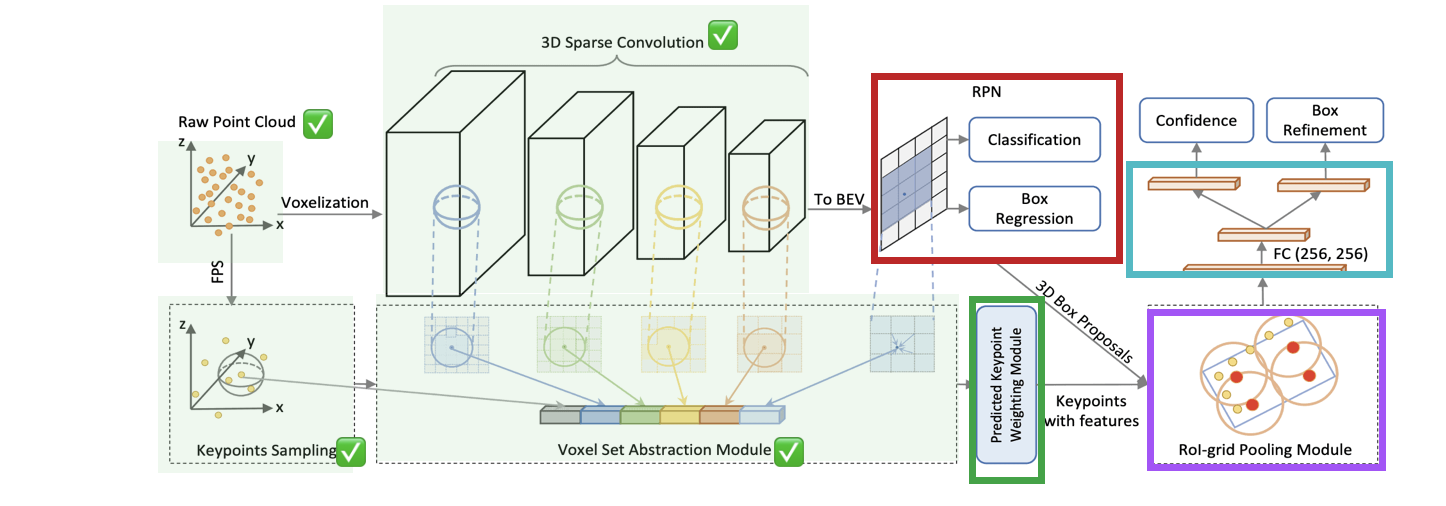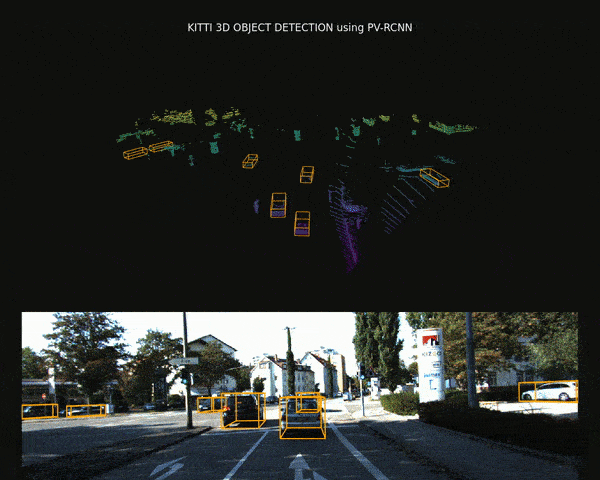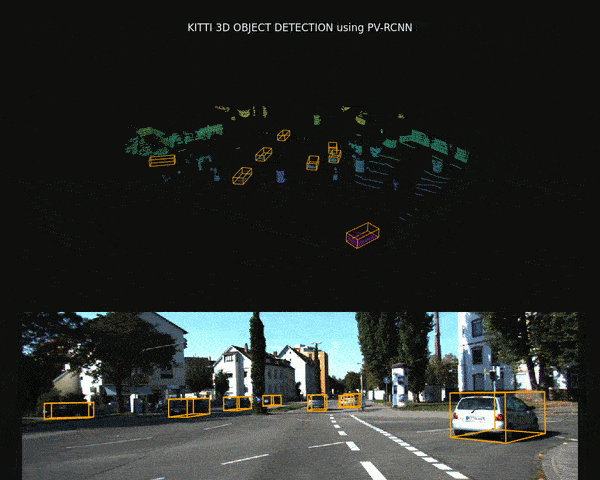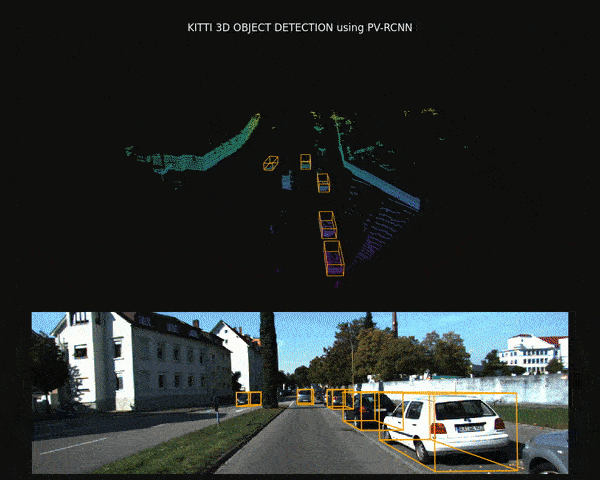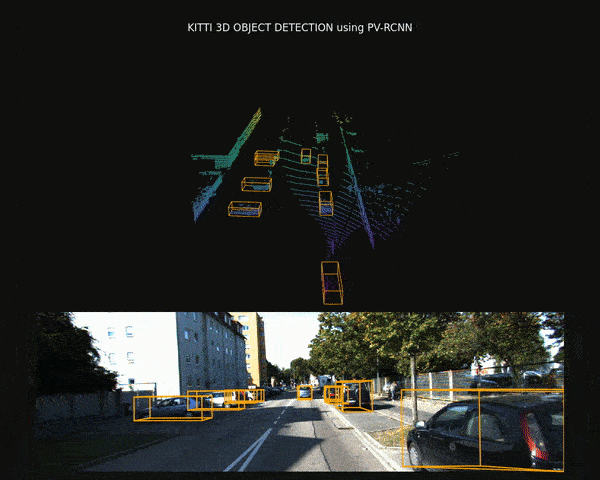
Congratulations, you're at the Terminus!
This is the final step in your LiDAR Journey. The moment where you will push your skills to the limits, and learn to build ultra advanced 3D networks.
One thing has been missing all along...
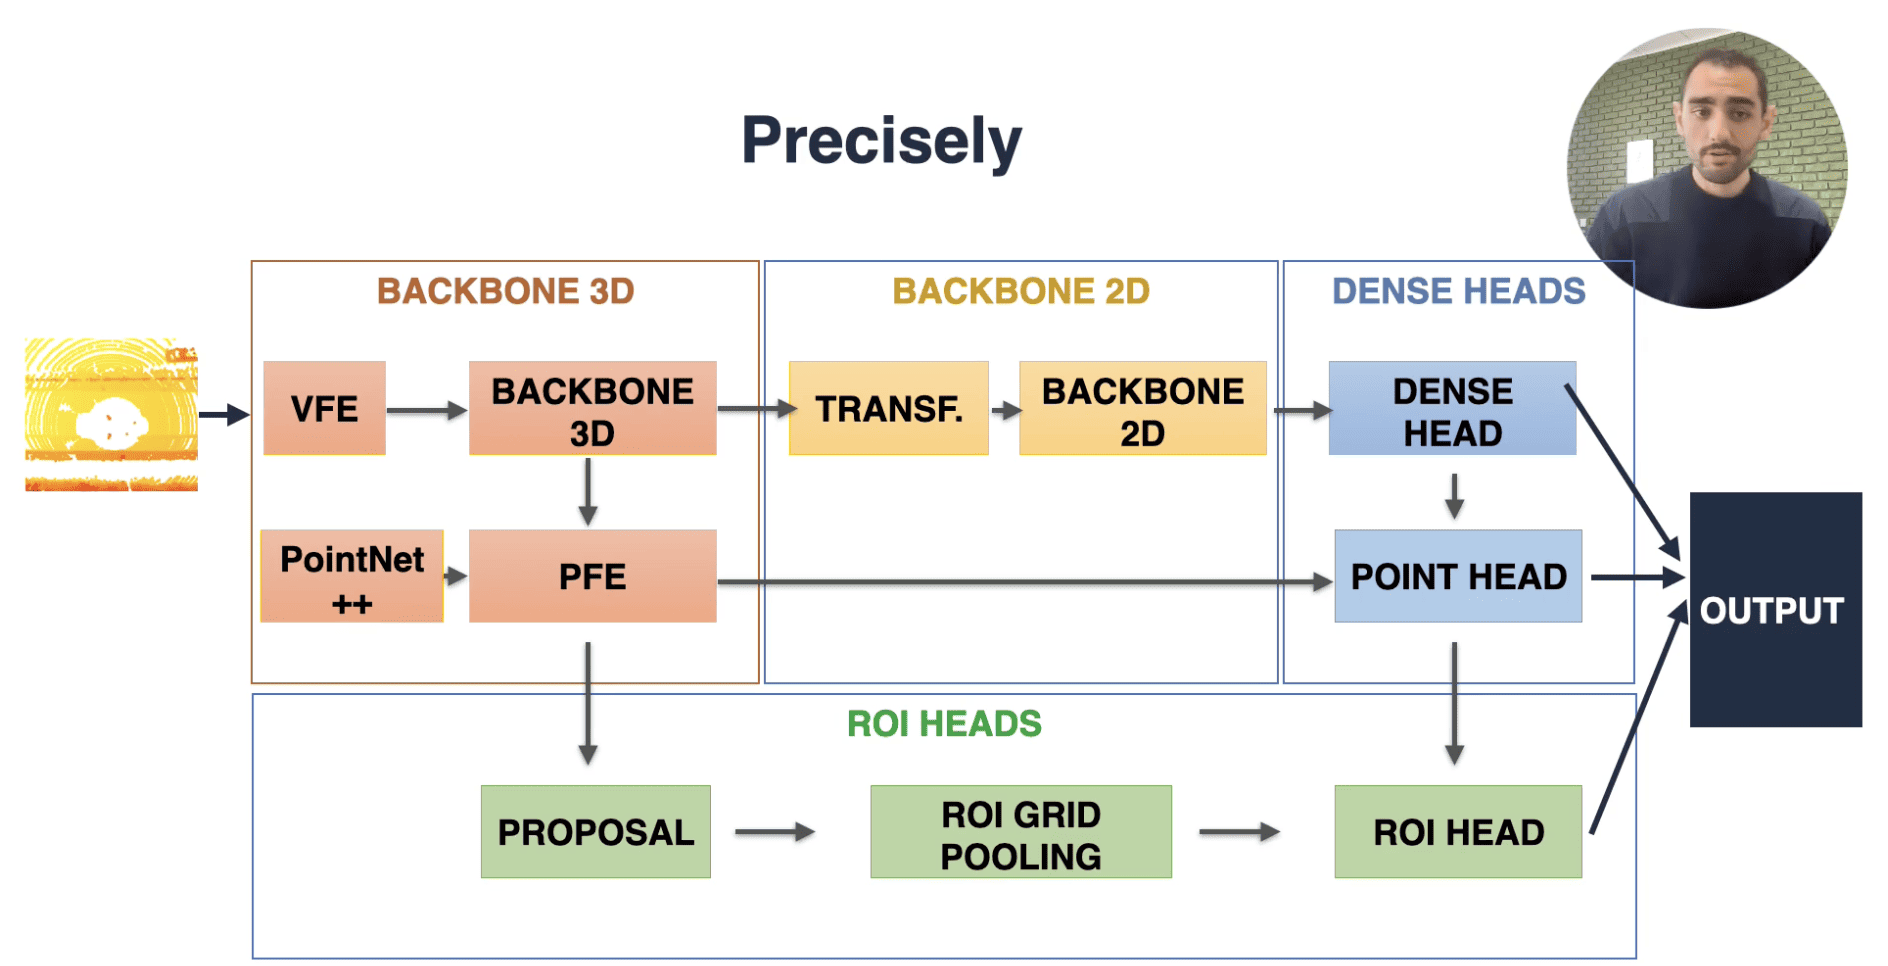
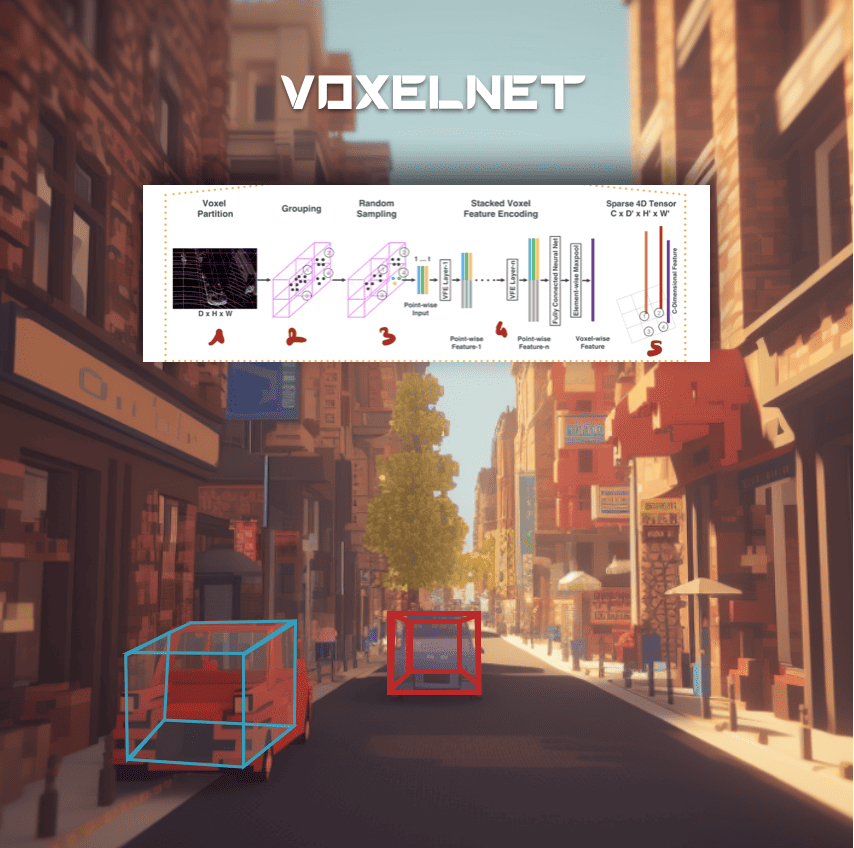
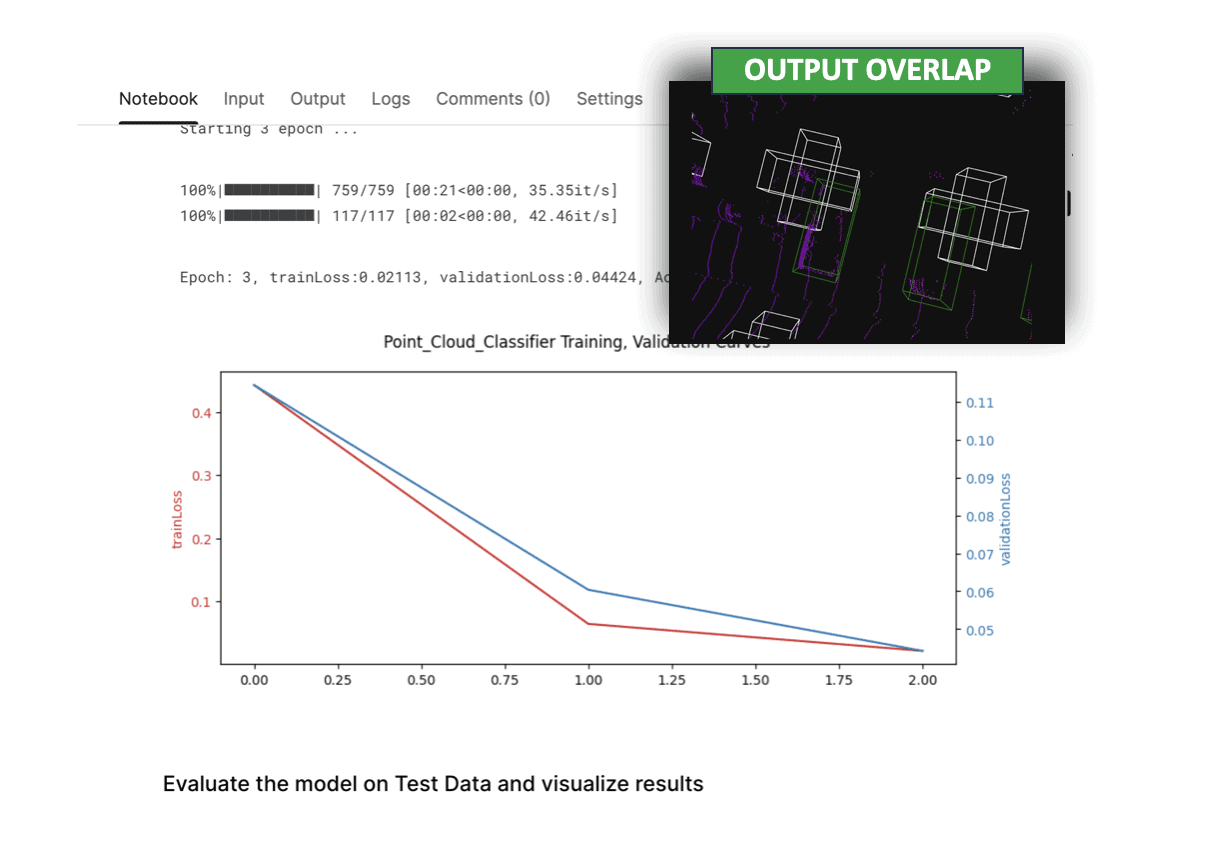
In the Deep Point Clouds course, we're building hardcore fundamentals on 3D Deep Learning. We're learning how to use PointNet, and we're learning how to use Voxelization & 3D CNNs.
But all of it really is the "backbone" to more practical algorithms.
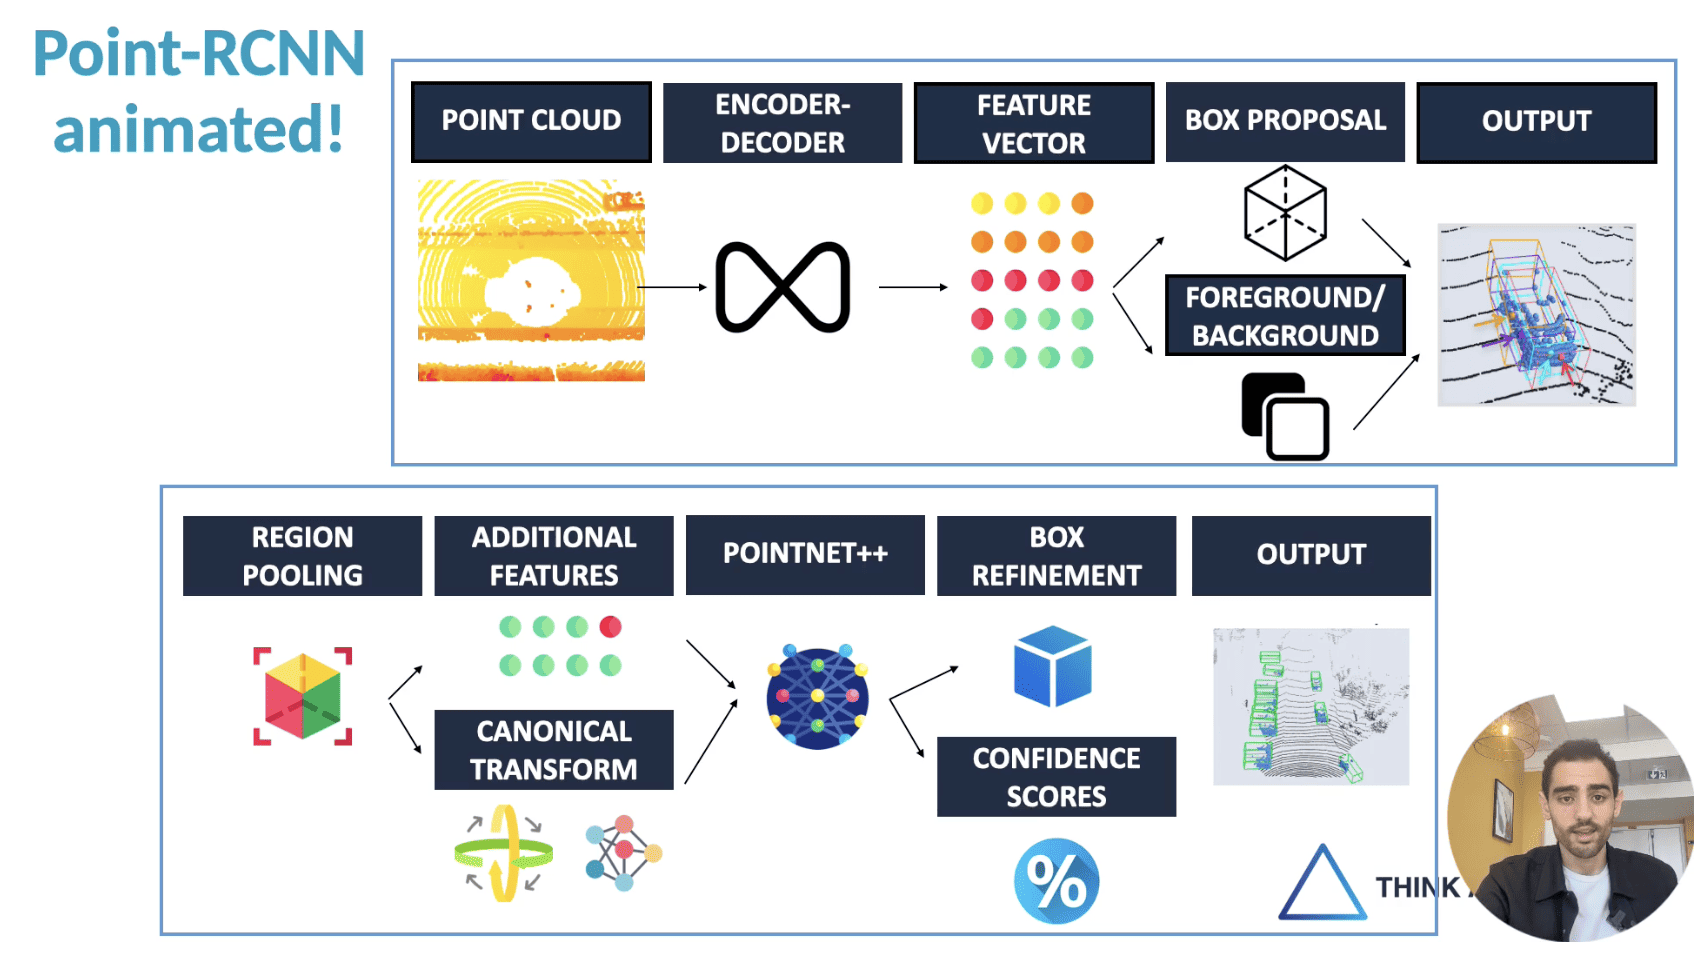
When you look around, you'll notice that engineers don't stick to using backbones and classifiers, they also learn to apply 3D Deep Learning in every day projects, like 3D Object Detection.
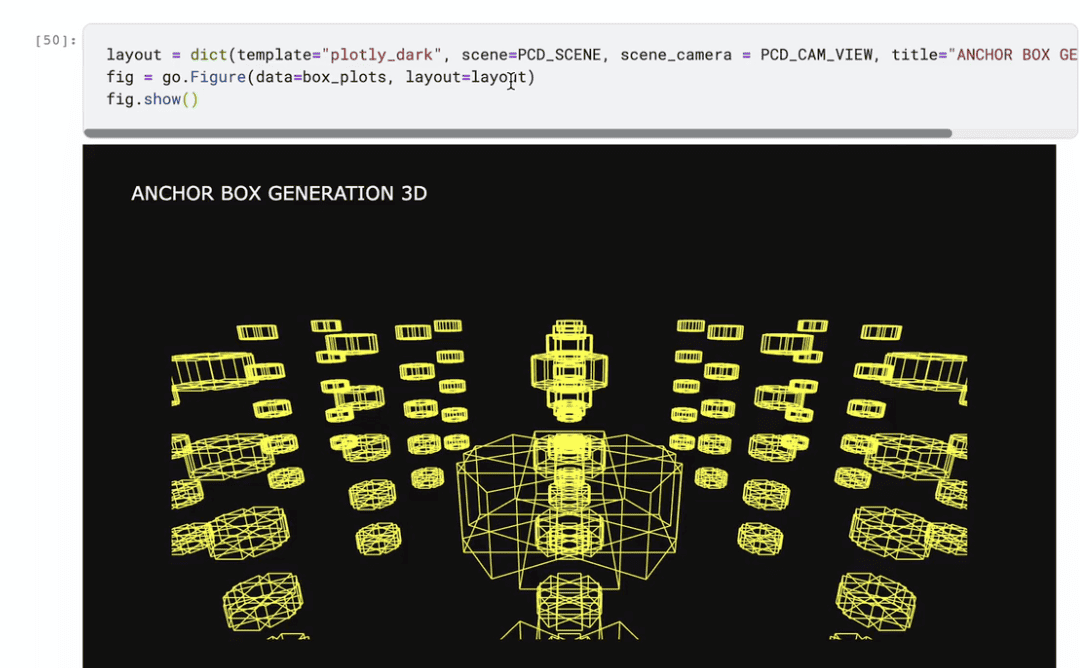
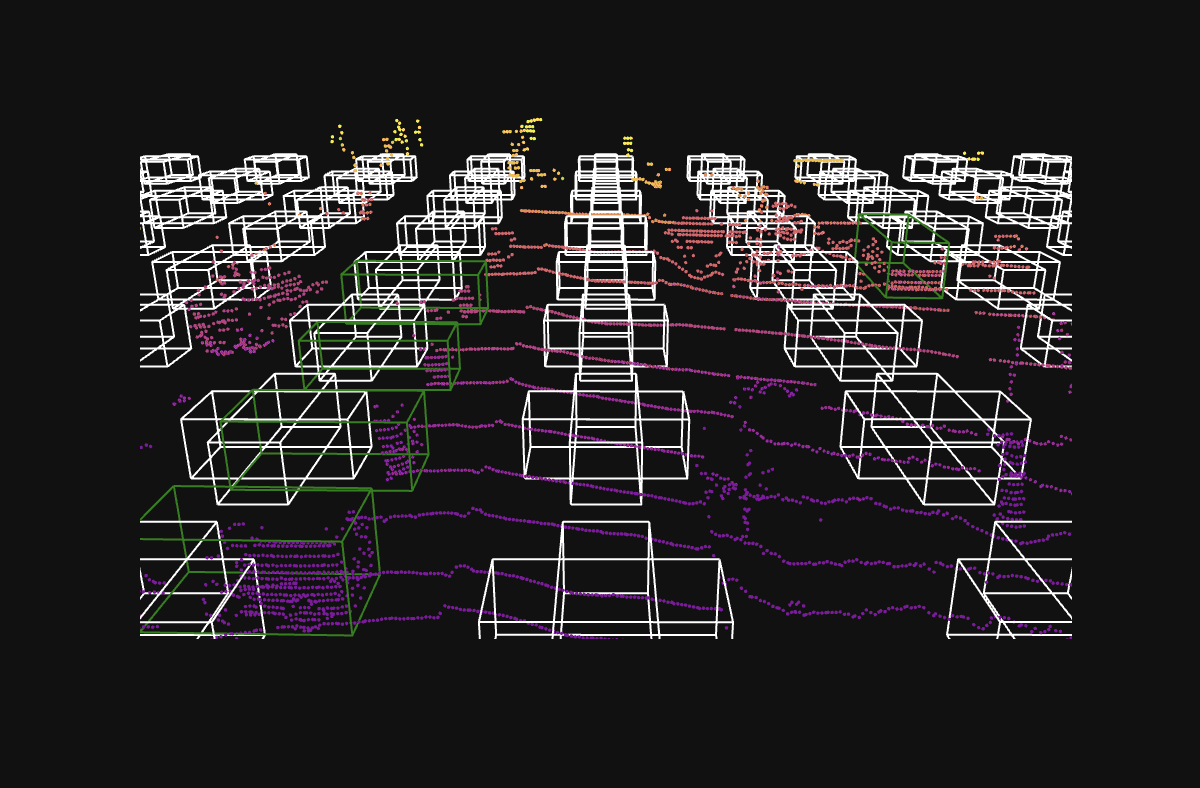
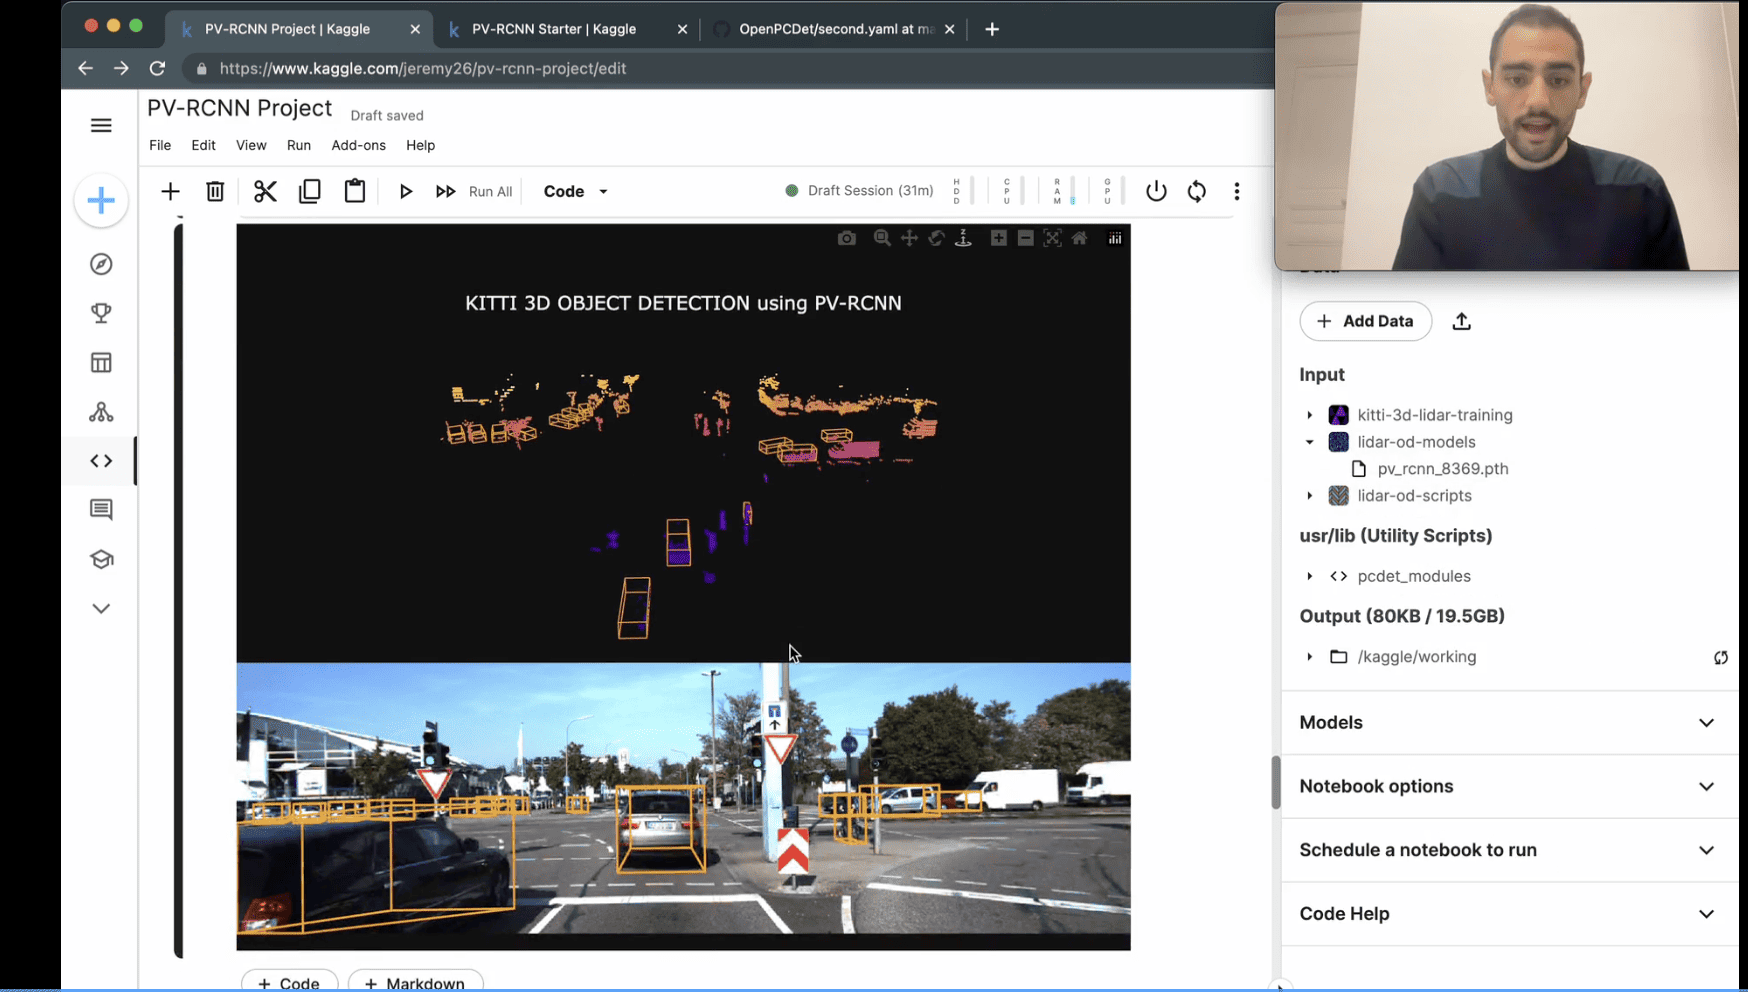
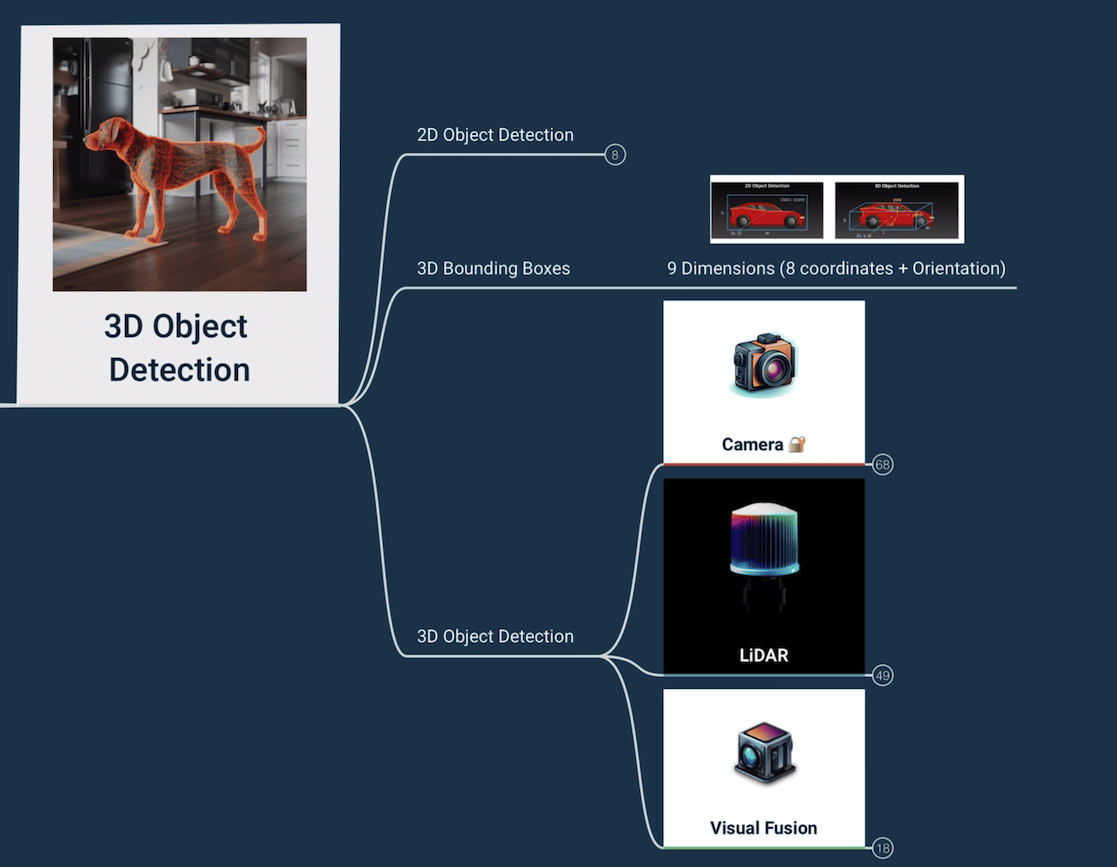
In LiDAR, 3D Object Detection is the most common and important application to master; and it was a missing element from my Deep Point Clouds course.
We have learned about classification, and it's now time to learn about object detection.
Just like with Computer Vision, most applications are based on object detection. Whether it's augmented reality, object recognition, drone tracking, autonomous driving, or any other; we must detect objects to understand our surroundings.
Self-Driving Car Companies heavily use LiDAR Object Detection
When you look at it this way; most companies rely on LiDAR. And most of these companies rely on object detection.
In fact, even non self-driving car companies who sell LiDARs and software use Self-Driving Car 3D Object Detection as example.
An example with Innoviz's Perception system:
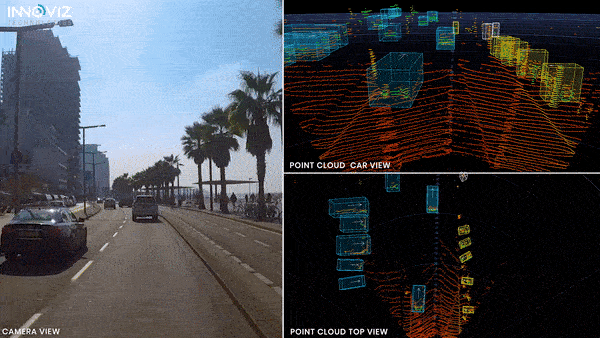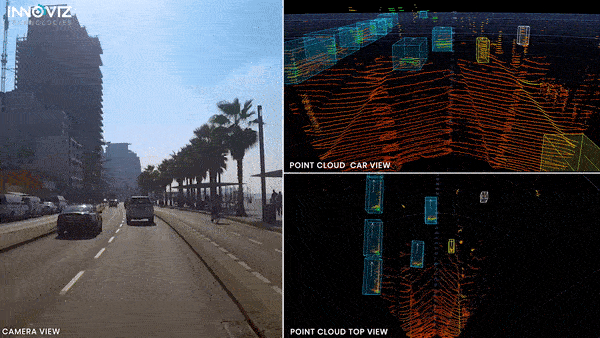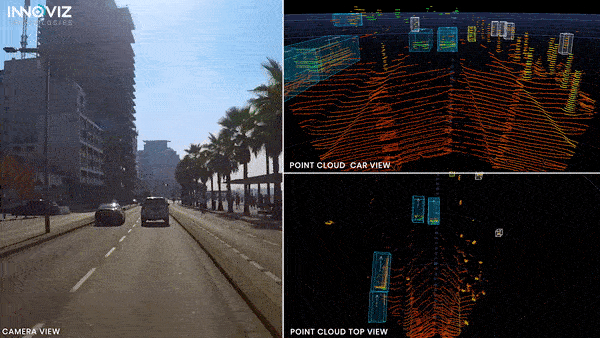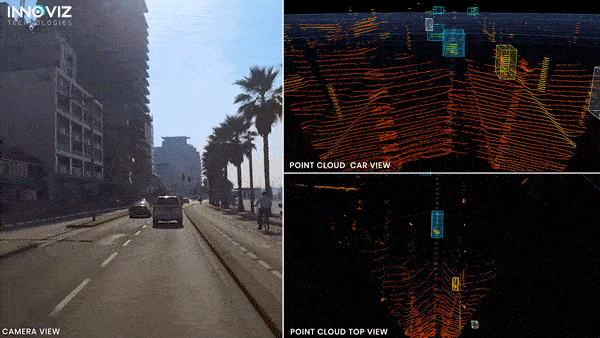
This is what this course is all about!
And I see this skill as the ultimate one to complete your journey in 3D Deep Learning.
These skills are valuable, valued, and hard to master. Going there alone would be pure madness, especially when a DLC exists and has everything already pathed for you.
This course is the only course you'll find on LiDAR Based Object Detection that teaches the blocks at this level. You may find videos explaining a few algorithms, or repositories showing how to run black boxes, but nothing will really help you "get it".
Until now...